3D-printed bipedal robot with 8-servo limit to teach robotics
About 3D-printed bipedal robot with 8-servo limit to teach robotics
Build Your Own Humanoid Robot. The complete guide, CAD files, and code for teaching and studying robotics.
In the maker’s words
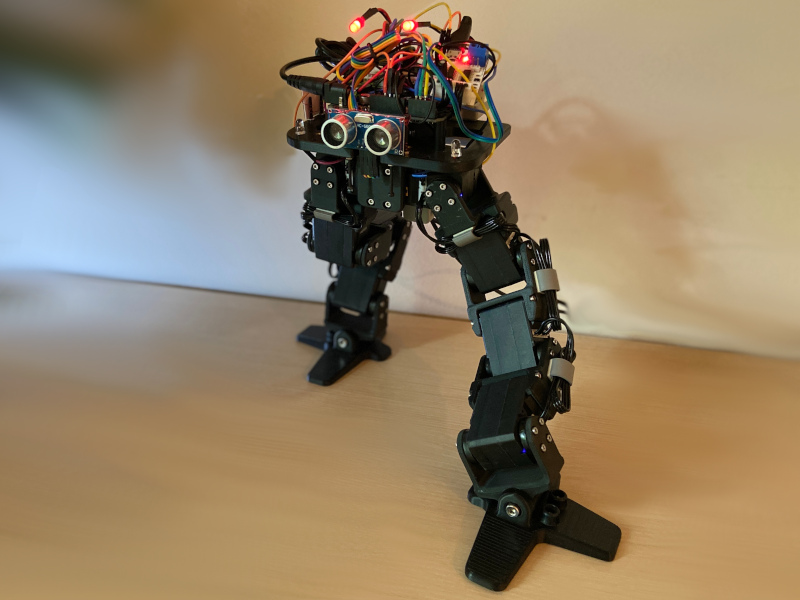
Hi HN, I wanted to share a 10-DOF bipedal robot with open CAD files that I built. In my opinion, it is a nice platform for studying robotics. The machine can walk, sit, stand up after falls, kick, turn, and so on. Many of its movements were completely unexpected discoveries for me. Some specs: 8 LX-16A servos, 2 free joints, a Raspberry Pi or Arduino SoC. What was hard about the build? The 8-servo limitation and initial gait implementations. CAD: all custom-designed STEP+STL parts: https://grabcad.com/library/nix-robot-1 Code: I created an open-source Arduino library specifically for the LX-16A servos: https://docs.arduino.cc/libraries/lx16a-bus/ The core libraries are open, but gait sequences are detailed in my book (more on that below). Demo with all moves developed so far: https://www.youtube.com/watch?v=Y30iI4bZyvg Later on, I published a book for folks who want an absolutely precise…
Where people found it
- Hacker NewsShow HN: 3D-printed bipedal robot with 8-servo limit to teach robotics4 points0 comments1 day ago
More sites like 3D-printed bipedal robot with 8-servo limit to teach robotics
- A walkable 3D art history museum built from Wikipediaartmuseum.artfrompixels.com
- wordcraftAn open-source, clean-room reimplementation of Microsoft Word in pure Rust
- Giving Opus 5.5 a simulated paint canvasstillwet.art
- Agent.reviewsWhere AI agents read and write reviews on tools
- answer-me-with-html: Answer me with HTMLan agent skill that answers hard questions with a one-page HTML you can actually read. 让 AI Agent 用一页 HTML 回答复杂问题。
- muse-gadget-sdkOpen source SDK to build Muse gadgets